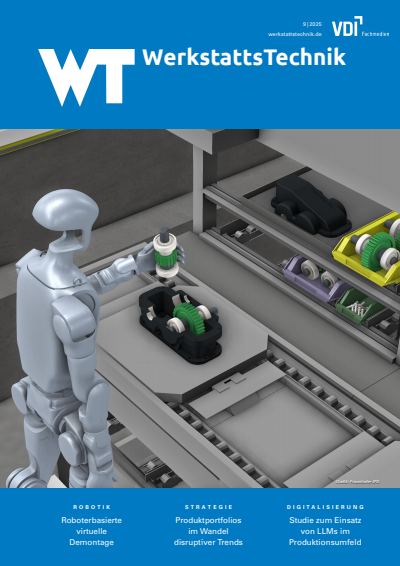
Roboterbasierte virtuelle Demontage/Robot-based virtual dissasembly
Table of contents
Bibliographic information
Open Access Full access
wt Werkstattstechnik online
Volume 115 (2025), Issue 09
- Authors:
- Publisher
- VDI fachmedien, Düsseldorf
- Copyright Year
- 2025
- ISSN-Online
- 1436-4980
- ISSN-Print
- 1436-4980
Chapter information
Open Access Full access
Volume 115 (2025), Issue 09
Roboterbasierte virtuelle Demontage/Robot-based virtual dissasembly
- Authors:
- ISSN-Print
- 1436-4980
- ISSN-Online
- 1436-4980
- Preview:
Data from CAE-based vehicle development enables planning, validation, and execution of automated disassembly and sorting according to R-strategies (reuse, recycle, recover, etc.). This paper addresses automated disassembly simulation, based on engineering data within virtual commissioning. Data continuity is ensured by adapting and linking existing partial solutions for the specific use case.
Bibliography
No match found. Try another term.
- [1] Werner, A.; Schuseil, F.; Hämmerle, M. et al.: Modular Digital Twin – an approach for generating and exploiting product sustainability information towards service-oriented business models. International Journal of Production Research 63 (2024) 3, pp. 992–1010, doi.org/10.1080/00207543.2024.2366997 Open Google Scholar DOI: 10.37544/1436-4980-2025-09-41
- [2] Jungbluth, J.: Entwicklung eines intelligenten, robotergestützten Assistenzsystems für die Demontage industrieller Produkte. PhD Thesis, Unilu – University of Luxembourg, Luxembourg, 2019 Open Google Scholar DOI: 10.37544/1436-4980-2025-09-41
- [3] Tian, G.; Ren, Y.; Feng, Y. et al.: Modeling and Planning for Dual-Objective Selective Disassembly Using AND/OR Graph and Discrete Artificial Bee Colony. IEEE Transactions on Industrial Informatics 15 (2019) 4, pp. 2456–2468, doi.org/10.1109/TII.2018.2884845 Open Google Scholar DOI: 10.37544/1436-4980-2025-09-41
- [4] Smith, S. S.; Chen, W.-H.: Rule-based recursive selective disassembly sequence planning for green design. Advanced Engineering Informatics 25 (2011) 1, pp. 77–87 Open Google Scholar DOI: 10.37544/1436-4980-2025-09-41
- [5] Neb, A.: Methodik zur automatischen Generierung von Montagesequenzen aus einem 3D-Modell. Dissertation, Universität Stuttgart, 2023 Open Google Scholar DOI: 10.37544/1436-4980-2025-09-41
- [6] Asif, M. E.; Rastegarpanah, A.; Stolkin, R.: Robotic disassembly for end-of-life products focusing on task and motion planning: A comprehensive survey. Journal of Manufacturing Systems 77 (2024), pp. 483–524 Open Google Scholar DOI: 10.37544/1436-4980-2025-09-41
- [7] Scheifele, C.; Verl, A.; Riedel, O.: Real-time co-simulation for the virtual commissioning of production systems. Procedia CIRP 79 (2019), pp. 397–402 Open Google Scholar DOI: 10.37544/1436-4980-2025-09-41